
Why are reflections important in pile driving simulations?
Reflections are important in pile driving simulations because they carry direct information about what is happening along the pile and at its toe during installation. Every change in soil resistance, pile geometry, or material properties generates a reflected stress wave that travels back up the pile. By analyzing these reflections, engineers can determine whether a pile is being driven correctly, whether the soil resistance is distributed as expected, and whether the pile itself remains structurally sound.
This applies to both impact driving and vibratory driving scenarios, and the principle underpins methods ranging from drivability prediction to Dynamic Load Testing. The sections below answer the most common questions about how reflections work and why they matter in practice.
How do stress waves travel through a pile during driving?
When a hammer strikes a pile, it generates a compressive stress wave that travels downward through the pile at a speed determined by the pile material. This speed, known as the stress wave velocity, is a fixed property of the pile material. For steel piles, this velocity is approximately 5,100 meters per second. The wave travels from the pile head toward the toe, interacting with the surrounding soil and the pile’s own geometry along the way.
The foundation of this analysis is one-dimensional stress wave theory, implemented using the Method of Characteristics (MoC). Rather than treating the pile as a rigid body, this approach recognizes that the hammer impact creates a traveling wave. Forces, velocities, displacements, and stresses all vary as a function of both time and depth. This makes it possible to calculate what is happening at any point along the pile at any moment during the blow.
Shaft resistance along the pile and toe resistance at the tip both act on the traveling wave. Shaft resistance slows and attenuates the downward wave progressively, while toe resistance produces a strong reflection at the pile tip. The interaction between the downward wave and these resistance sources determines how much energy is transferred to the soil and how much permanent penetration occurs with each blow.
What causes reflections in pile driving simulations?
Reflections in pile driving simulations are caused by any discontinuity that the stress wave encounters as it travels through the pile. The three main sources are changes in pile impedance, shaft resistance along the pile, and toe resistance at the pile tip. Each of these generates a reflected wave that travels back toward the pile head.
Pile impedance is the product of the pile’s cross-sectional area, material stiffness, and wave velocity. When the wave reaches a section where impedance changes, such as a narrowing, a crack, or a joint, part of the wave reflects and part continues downward. The character of the reflection reveals whether the impedance increased or decreased at that point.
Shaft resistance generates upward-traveling reflections continuously as the wave moves down the pile. Each soil layer that resists the pile’s movement sends a reflected signal back toward the head. The timing of these reflections corresponds to the depth at which the resistance acts.
Toe resistance produces the most prominent reflection in most driving scenarios. When the downward wave reaches the pile tip and encounters the soil below, a strong compressive reflection travels back up. The amplitude and timing of this toe reflection are directly related to the magnitude of the resistance at the pile tip and the depth of the pile.
What information do reflections reveal about soil resistance?
Reflections reveal both the location and magnitude of soil resistance acting on the pile. Because the stress wave travels at a known velocity, the timing of a reflected signal tells you where along the pile that resistance is acting. A reflection arriving after a time interval of 2x/c, where x is depth and c is wave velocity, originates from a resistance source at depth x.
This timing principle makes it possible to distinguish shaft resistance at different depths from toe resistance at the pile tip. In signal matching analysis, engineers adjust the assumed soil resistance distribution in the model until the simulated signals match the measured ones. The depth-dependent timing of reflections is one of the primary tools for separating shaft and toe contributions.
The shape and amplitude of the reflected signals also carry information about soil damping and quake. Damping at a given depth influences the reflected signal arriving at approximately 2x/c after the initial impact. Quake, which is the elastic deformation of the soil before plastic displacement begins, affects the shape of the signal after the first major return reflection. Together, these parameters define how the soil responds dynamically during each blow, which directly affects the blow count and the energy required to advance the pile.
An important practical point is that a resistance value derived from signal matching is only reliable if that resistance was actually mobilized during the blow being analyzed. Toe resistance typically mobilizes later than shaft resistance because the pile must compress elastically before the toe displacement is large enough to fully engage the soil. A clear toe reflection helps confirm whether full mobilization occurred.
How do reflections help detect pile defects and integrity issues?
Reflections help detect pile defects because any change in the pile’s cross-section or material properties generates a reflected wave, just as soil resistance does. A crack, void, or significant reduction in cross-sectional area causes a reflection that arrives earlier than the toe reflection and has a characteristic shape that differs from a soil resistance reflection.
In Sonic Integrity Testing, a low-energy impact is applied to the pile head and the resulting stress wave reflections are recorded. Because the test uses a small hammer and the pile is not being driven, the reflections come almost entirely from changes in the pile itself rather than from soil resistance. A clean pile with uniform cross-section produces a clear toe reflection with minimal intermediate signals. Defects appear as earlier, often sharper reflections between the pile head and the toe.
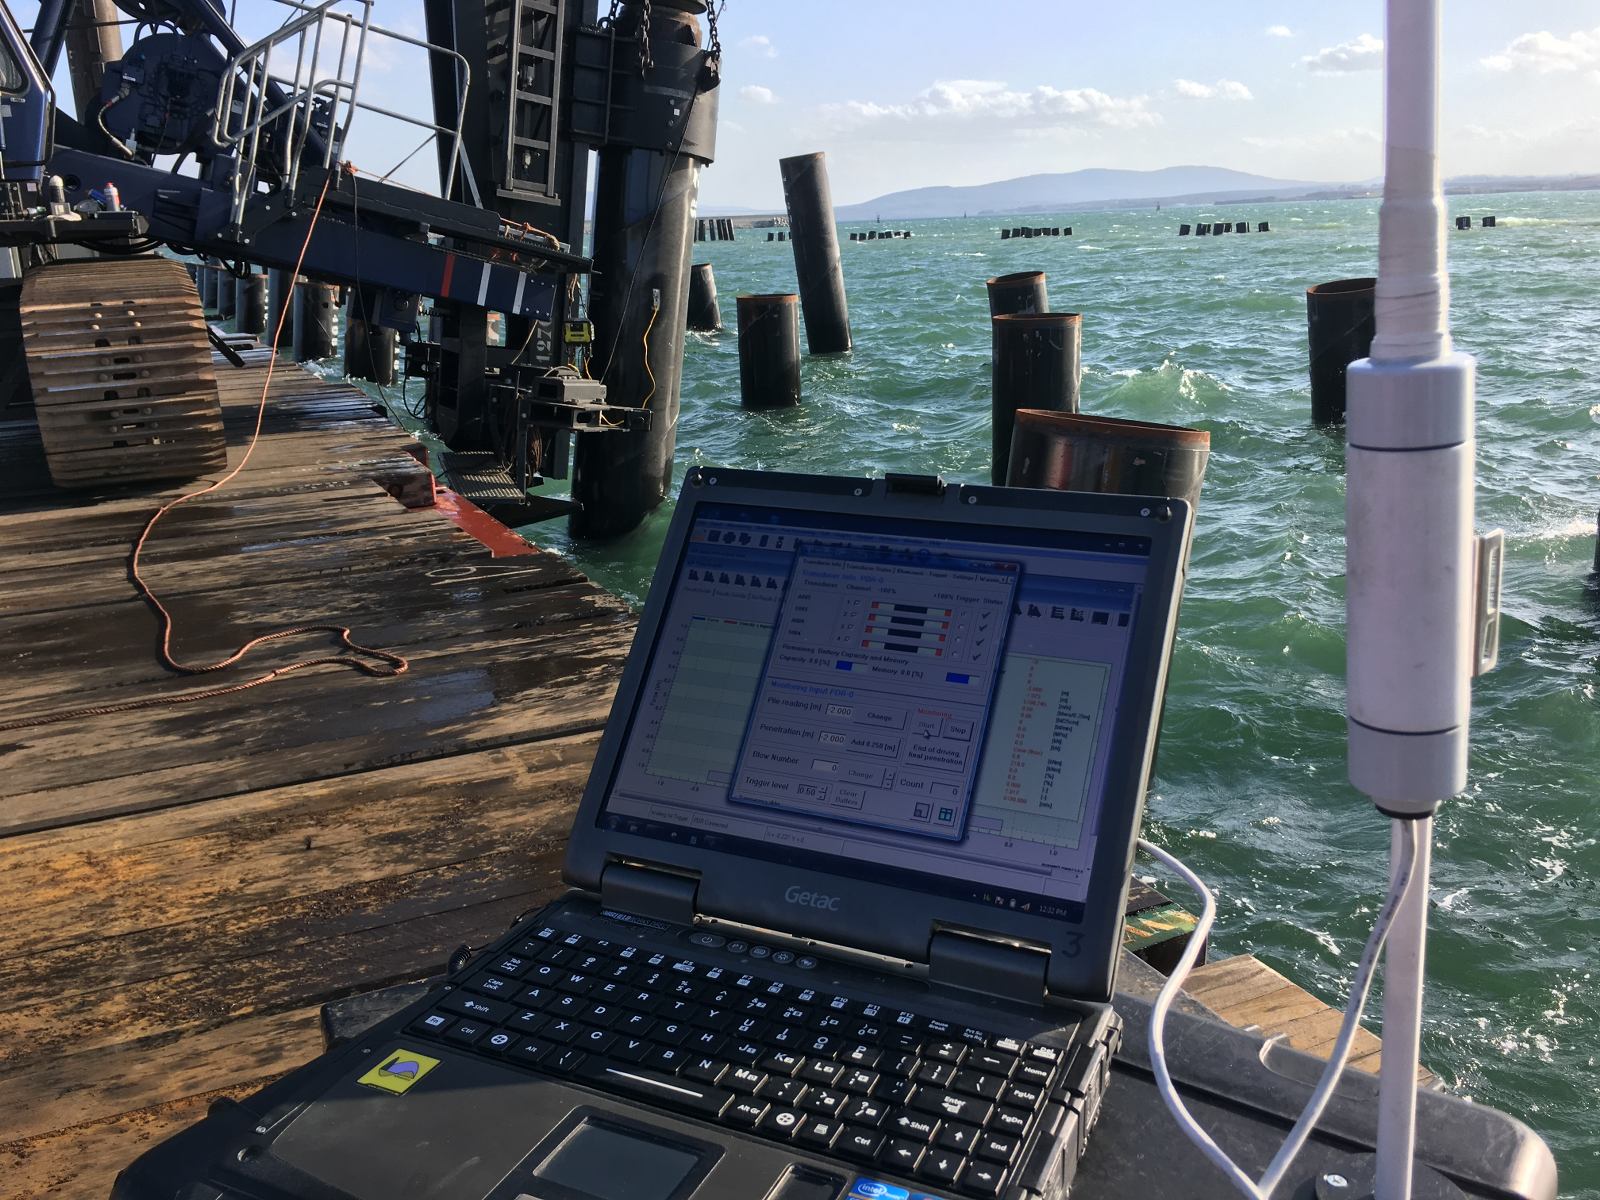
During dynamic load testing and drivability analysis, the same principle applies. If a pile develops a crack during driving, the impedance at that location changes and a new reflection appears in the measured signal. Engineers monitoring the signals in real time can detect this change and assess whether driving should continue. The depth of the defect can be estimated from the arrival time of the reflection using the known wave velocity of the pile material.
What happens when reflections are ignored or misinterpreted in simulations?
When reflections are ignored or misinterpreted in pile driving simulations, the result is an inaccurate picture of soil resistance, pile integrity, or both. This can lead to incorrect blow count predictions, underestimated pile stresses, or a false assessment of the pile’s bearing capacity.
A common misinterpretation occurs when a reflection from a soil resistance source is mistaken for a structural defect, or vice versa. Because both generate reflected waves, distinguishing between them requires careful analysis of timing, amplitude, and signal shape. Misidentifying the source leads to wrong conclusions about either the soil model or the pile condition.
In drivability prediction, ignoring the information carried by reflections means the soil model cannot be properly calibrated. If the simulated signals do not match the measured ones, the assumed resistance distribution is wrong. Driving ahead with an incorrect model increases the risk of early refusal, pile overstress, or reaching the target depth with insufficient bearing capacity. These outcomes can require costly remedial actions, including switching to a larger hammer, removing soil plugs, or redesigning the installation approach entirely.
A mathematically good numerical fit between simulated and measured signals is not sufficient on its own. The resulting soil parameters must also be physically plausible. A model that fits the signals but produces unrealistic damping values or resistance distributions should not be trusted, even if the curve match looks acceptable.
How do modern pile driving simulation tools model reflections?
Modern pile driving simulation tools model reflections by solving the one-dimensional wave equation numerically for each time step of the blow. The pile is divided into segments, and the stress wave propagates from segment to segment, with soil resistance applied at each node. At every interface, the tool calculates both the transmitted and reflected components of the wave based on impedance differences and resistance forces.
The AllWave software package uses the Method of Characteristics to simulate stress wave propagation for both impact driving and vibratory driving. AllWave-PDP handles impact driving scenarios and produces outputs including blow count versus penetration depth, maximum tension and compression stresses, energy transfer, and pile displacement. AllWave-VDP addresses vibratory driving, where the loading mechanism and soil response differ significantly from impact driving. In vibratory driving, the soil undergoes thousands of cycles, and the model must account for how soil strength degrades with repeated loading, a phenomenon known as friction fatigue.
For vibratory driving, the eccentric moment, operating frequency, and displacement amplitude of the hammer all influence how the pile interacts with the soil and how reflections develop. Two hammers with similar centrifugal force but different eccentric moments and frequencies can produce very different penetration rates, particularly in cohesive soils where sufficient toe displacement is needed to move the soil beyond its elastic range.
In signal matching for Dynamic Load Testing, the tool iterates the soil resistance model until the simulated force and velocity signals at the pile head match the measured ones. The timing of reflections in the simulated signal is compared directly to the measured signal to verify that resistance is assigned to the correct depths. Sensitivity analysis, varying parameters between realistic minimum and maximum values, helps establish the range of plausible solutions and avoids over-reliance on a single best-fit result.
How We Help with Pile Driving Simulation and Reflection Analysis
We combine decades of experience in stress wave analysis with our own simulation tools to give your team a complete picture of pile installation behavior, from the first blow to the target penetration depth.
- Drivability studies using AllWave-PDP and AllWave-VDP: We simulate the full installation process for both impact and vibratory driving, predicting blow count, pile stresses, energy transfer, and refusal risk at every penetration level.
- Soil modeling for pile driving: We build soil resistance models from CPT, SPT, and laboratory data, calibrated against the reflection patterns observed in measured signals to ensure the model reflects actual ground conditions.
- Signal matching and Dynamic Load Testing analysis: We analyze measured force and velocity signals to determine shaft and toe resistance distributions, using reflection timing and amplitude to validate the resistance model at depth.
- Pile integrity assessment: We interpret reflection signals to identify structural anomalies, including cracks, voids, and cross-section changes, during both testing and installation monitoring.
- Risk quantification: We assess the uncertainty in soil resistance predictions and provide upper and lower bound scenarios so your team can plan for realistic installation outcomes rather than a single optimistic estimate.
If your project involves complex soil conditions, offshore installation, or piles where integrity and bearing capacity both need to be verified, contact us to discuss how we can support your drivability analysis and pile testing program.